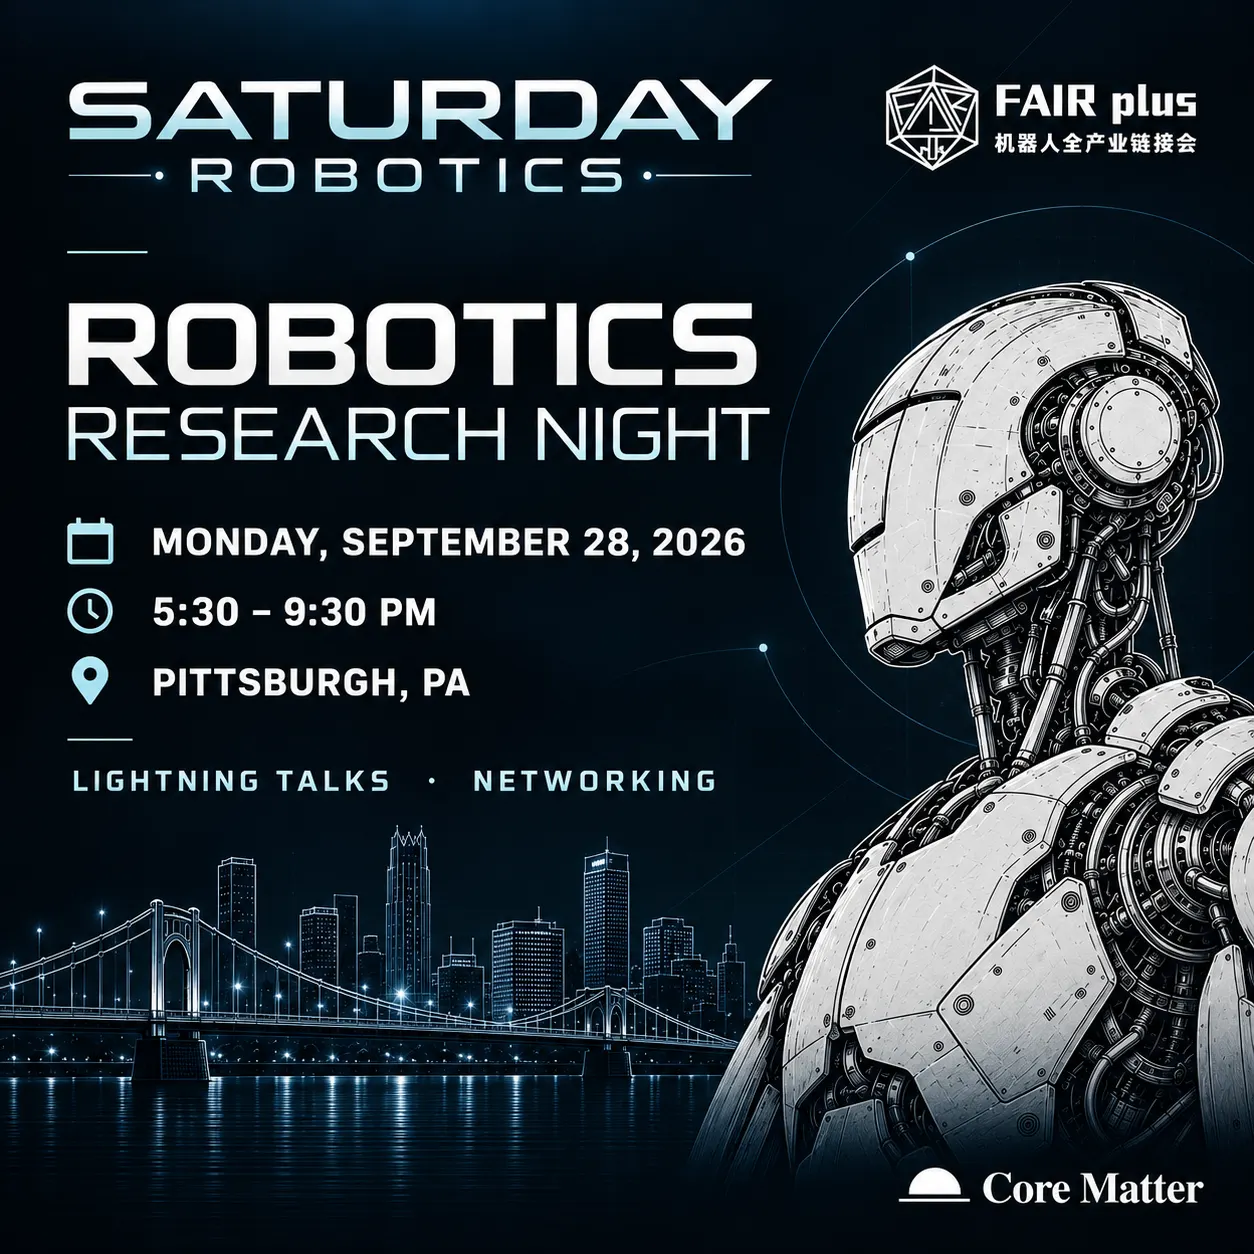
🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28
🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28 takes place on Mon, Sep 28, 2026 at 5:30 PM (EDT) in Pittsburgh, PA, and runs until 9:30 PM. Entry is free; the listing is on Luma.
About this event
🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28 📅 Monday, September 28🕠 5:30 PM – 9:30 PM📍 Pittsburgh, PA (walking distance from David L. Lawrence Convention Center) About Event
Read full descriptionShow less
After a full day of technical sessions at IROS 2026, join Saturday Robotics for an evening of high-signal technical discussions, lightning talks, and networking with researchers, founders, engineers, investors, and students building the future of robotics. Saturday Robotics has become one of Silicon Valley's largest community-driven robotics research groups, bringing together researchers from Google DeepMind, NVIDIA, Stanford, UC Berkeley, CMU, MIT, Physical Intelligence, Tesla, Figure, Agility Robotics, Skild AI, Boston Dynamics, and many leading robotics startups. Support Saturday Robotics Inc: https://donate.stripe.com/28EcN52rjgeY1fJboYgEg00 This event is brought to you by FAIR Plus, our title sponsor. FAIR Plus is an annual trade exhibition and technology exchange platform held in Shenzhen, China, focusing on artificial intelligence, hardware development, and robotics. Their upcoming exhibition is April 21-23, 2027. Whether you're presenting at IROS, recruiting collaborators, building a startup, or simply interested in meeting others working on Physical AI, we'd love to see you in Pittsburgh. Agenda 🕠 5:30 PM – 6:00 PMDoors Open & Happy Hour Networking Grab a drink, meet fellow attendees, reconnect with old friends, and make new ones before the technical sessions begin. 🕕 6:00 PM – 7:30 PMLightning Talk 1 Lizhi(Gary) Yang is a Ph.D. candidate in Mechanical Engineering at Caltech, advised by Professor Aaron Ames in the AMBER Lab. Lizhi’s research focuses on humanoid robotics, robot safety, and learning-based control. Today, He will present PAC-MAN, a framework that combines onboard perception, reinforcement learning, and control barrier functions to teach humanoid robots to dodge incoming objects while staying balanced. The work explores how perception and safety must be designed together for fast, whole-body robot reactions. https://arxiv.org/abs/2607.28623v1 PAC-MAN: Perception-Aware CBF-RL for Whole-Body Safety in Humanoid Dodgeball presents a perception-aware reinforcement learning framework designed to improve the safety and robustness of humanoid robots operating in dynamic environments. The work combines Control Barrier Functions (CBFs) with reinforcement learning and realistic onboard perception, addressing a key challenge in robot learning: policies can achieve impressive performance but may behave unsafely when exposed to unexpected disturbances or imperfect observations.The system is demonstrated on a Unitree G1 humanoid robot performing a dynamic dodgeball task. During deployment, the robot relies only on proprioception and depth information from a head-mounted RGB-D camera. A segmentation model isolates the incoming ball from the depth image, creating a compact perception representation that closely matches the training setup. This design reduces the sim-to-real gap and allows the learned policy to operate without additional fine-tuning.PAC-MAN introduces two levels of CBF-based safety guidance. Link-CBF represents collision clearance for every robot body link, rather than protecting only the torso. The safety constraint is incorporated into the training reward, encouraging the policy to learn collision-free behavior directly. Importantly, no runtime safety filter is required during deployment. Joint-CBF, meanwhile, provides stronger guidance through joint-space constraints and can serve as a privileged safety filter during training or evaluation, although its effectiveness depends strongly on accurate perception of the approaching object.The framework also incorporates an adversarial human-motion prior, encouraging natural evasive behaviors such as ducking, sidestepping, leaning, and jumping. In real-world experiments, the G1 successfully dodged 19 of 20 throws (95%) with zero falls, while using onboard perception and no policy fine-tuning. The results demonstrate that integrating perception-aware safety constraints directly into robot learning can produce more robust, transferable, and deployment-ready whole-body behaviors for humanoid robots. Lightning Talk 2 Aaron Li (Rhoda AI, Robot Data System Lead, Research Member of Technical Staff) How in-context learning is reshaping robot learning data at scale. Lightning Talk 3 X2Real: an eXtensive simulation benchmark for real-world generalist policies Liangwang Ruan, X Square Robot, Simulation Tech Lead Generalist robot manipulation policies have developed rapidly, yet their reliable evaluation remains challenging due to fundamental flaws in existing simulation benchmarks: prominent sim-to-real gaps, narrow task coverage, and unfair evaluation caused by ambiguous training-test pipelines. Prior works only partially resolve these issues and lack simultaneous faithfulness, diversity, and fairness, while static benchmark designs fail to sustain long-term policy development. We presents X2Real, an evolvable simulation benchmark for faithfully evaluating the real-world performance of robotic manipulation policies. Following three core principles—faithfulness, diversity, and fairness—X2Real calibrates simulation visual and physical properties to align with real hardware, achieving a 0.84 linear correlation between simulated and real-robot evaluation results. It features a comprehensive taxonomy with 10 capability dimensions and 44 hierarchical long-horizon tasks, covering basic manipulation skills and advanced capacities such as visual grounding, language understanding, and bimanual control. We further adopt multi-axis domain randomization and strictly disjoint training-evaluation pipelines to mitigate benchmark exploitation and ensure credible evaluation. Powered by a custom physical domain-specific language, the Mana simulation ecosystem supports modular task design and iterative performance analys
Keep going
All Pittsburgh events →Similar events
View all →
Details
- When
- Mon, Sep 28, 2026 · 5:30 PM (EDT) · until 9:30 PM
- Where
- Pittsburgh, PA
- Price
- Free
- Weather
- 71°F · ClearForecast at 5:30 PM (EDT)
Questions
- When is 🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28?
- Mon, Sep 28, 2026 at 5:30 PM EDT.
- How much are tickets for 🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28?
- Entry is free.
- Where is 🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28?
- Pittsburgh, PA.
- Where can I buy tickets for 🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28?
- Tickets are sold on Luma. This page links straight to that listing; no tickets are sold here.
- What time does 🍾 IROS 2026 x Saturday Robotics x FAIR Plus — Robotics Research Night | Reading Club 31. Pittsburgh 9/28 end?
- It runs until 9:30 PM.